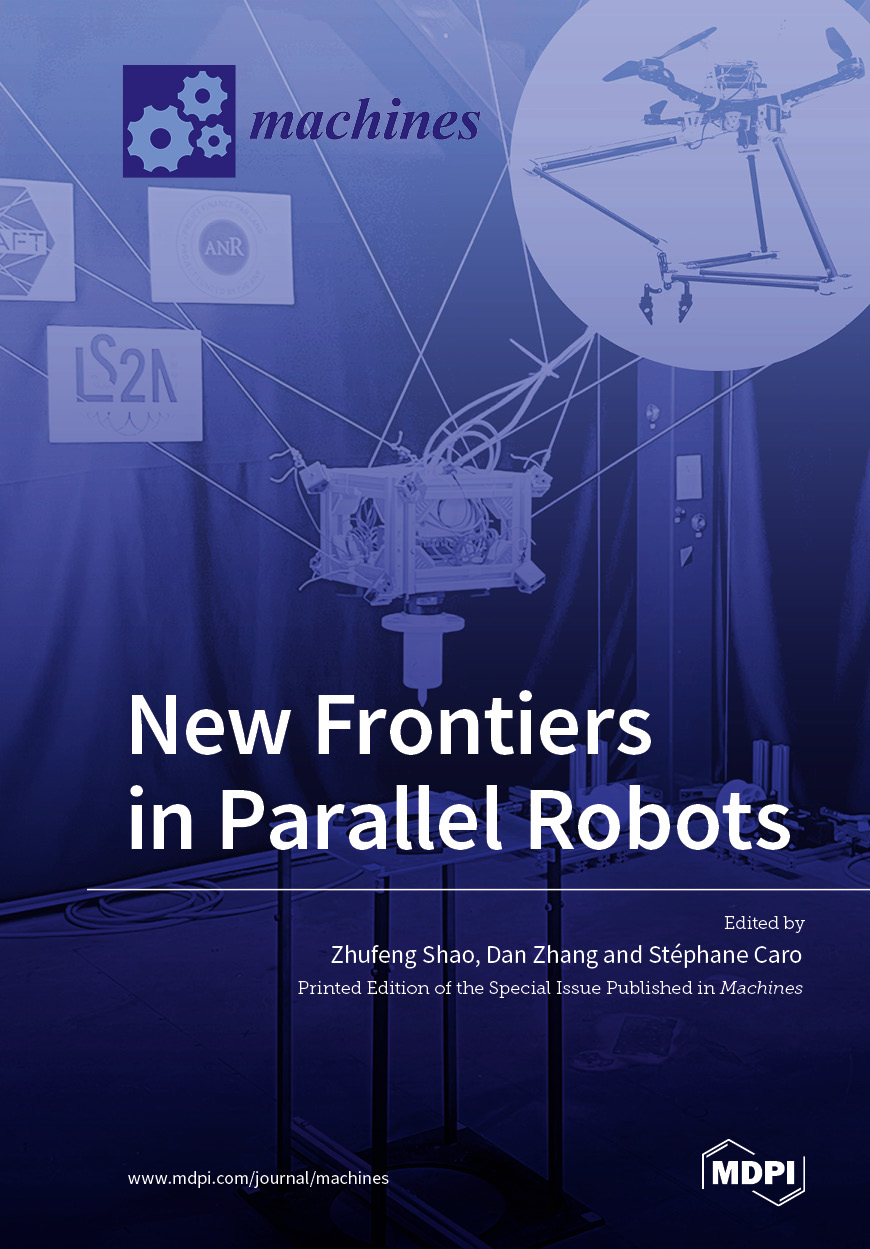
| Judul | New Frontiers in Parallel Robots / Shao, Zhufeng (editor) Zhang, Dan (editor) Caro, Stéphane (editor) |
| Pengarang | Shao, Zhufeng (editor) Zhang, Dan (editor) Caro, Stéphane (editor) |
| Penerbitan | Basel : MPDI, 2023 |
| Deskripsi Fisik | 240 :ill. ;25 cm |
| ISBN | 9783036572529 |
| Subjek | Parallel robots |
| Abstrak | The parallel robot, a kind of robot that utilizes multiple closed-loop branch chains jointly connecting and driving the moving platform, is an important part of modern robotics, with outstanding advantages of high stiffness, high precision and high speed. Parallel robots can efficiently change performance through the configuration of synthesis and design. The rich variety of configurations and the existence of a large number of passive joints also brought abundant challenges and research topics to the modeling, optimization, calibration and trajectory planning of parallel robots. This reprint focuses on the research frontiers of parallel robots from fundamental theory to application technology. Special attention is paid to kinematics/dynamics modeling, error modeling and calibration, impedance control and the machining stability of parallel robots. Notably, a considerable portion of the book focuses on cable-driven parallel robots (CDPRs) that integrate cable-driven kinematic chains and parallel mechanism theory. CDPRs inherit the high dynamics and heavy load capacities of parallel robots and significantly improve the workspace, cost and energy efficiency simultaneously, following the cutting-edge trend of rigid–flexible fusion. |
| Bentuk Karya | Tidak ada kode yang sesuai |
| Target Pembaca | Tidak ada kode yang sesuai |
| Lokasi Akses Online |
https://mdpi.com/books/pdfview/book/7554 |
| No Barcode | No. Panggil | Akses | Lokasi | Ketersediaan |
|---|---|---|---|---|
| 10 | 629.892 New | Dapat dipinjam | Perpustakaan Pusat - Online Resources Ebook |
Tersedia
pesan |
| Tag | Ind1 | Ind2 | Isi |
| 001 | INLIS000000000168875 | ||
| 005 | 20260605054206 | ||
| 007 | ta | ||
| 008 | 260605################|##########|#|## | ||
| 020 | # | # | $a 9783036572529 |
| 035 | # | # | $a 0010-0626000120 |
| 082 | # | # | $a 629.892 |
| 084 | # | # | $a 629.892 New |
| 245 | # | # | $a New Frontiers in Parallel Robots /$c Shao, Zhufeng (editor) Zhang, Dan (editor) Caro, Stéphane (editor) |
| 260 | # | # | $a Basel :$b MPDI,$c 2023 |
| 300 | # | # | $a 240 : $b ill. ; $c 25 cm |
| 520 | # | # | $a The parallel robot, a kind of robot that utilizes multiple closed-loop branch chains jointly connecting and driving the moving platform, is an important part of modern robotics, with outstanding advantages of high stiffness, high precision and high speed. Parallel robots can efficiently change performance through the configuration of synthesis and design. The rich variety of configurations and the existence of a large number of passive joints also brought abundant challenges and research topics to the modeling, optimization, calibration and trajectory planning of parallel robots. This reprint focuses on the research frontiers of parallel robots from fundamental theory to application technology. Special attention is paid to kinematics/dynamics modeling, error modeling and calibration, impedance control and the machining stability of parallel robots. Notably, a considerable portion of the book focuses on cable-driven parallel robots (CDPRs) that integrate cable-driven kinematic chains and parallel mechanism theory. CDPRs inherit the high dynamics and heavy load capacities of parallel robots and significantly improve the workspace, cost and energy efficiency simultaneously, following the cutting-edge trend of rigid–flexible fusion. |
| 650 | # | # | $a Parallel robots |
| 700 | 0 | # | $a Shao, Zhufeng (editor) Zhang, Dan (editor) Caro, Stéphane (editor) |
| 856 | # | # | $a https://mdpi.com/books/pdfview/book/7554 |
| 990 | # | # | $a 10 |
| 990 | # | # | $a 10 |
Content Unduh katalog